Follow a clear path through difficult ideas.
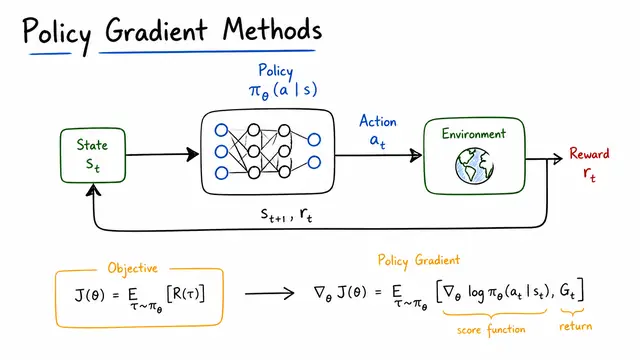
Move from policy gradients and search to practical robot learning with demonstrations and human feedback.