Search the public knowledge base.
12 results
An interactive series you work through: predict, play, derive and break things, from Dyna to every trick inside DreamerV3, ending with a world model you drive in your browser.
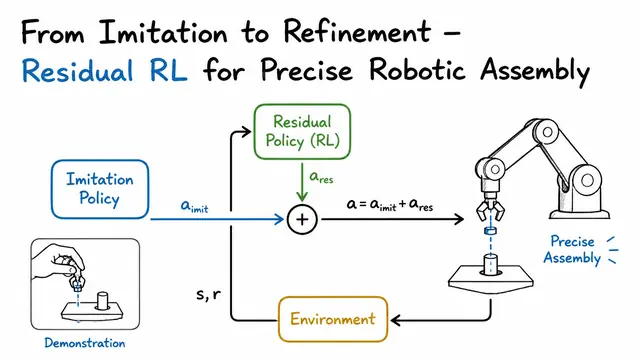
Imagine training a robot arm from a replay buffer that contains plenty of examples of ordinary motions—move left, move right, lower ...
A diagram-rich generated explanation from the public library.
A diagram-rich generated explanation from the public library.
A diagram-rich generated explanation from the public library.
A diagram-rich generated explanation from the public library.
A diagram-rich generated explanation from the public library.
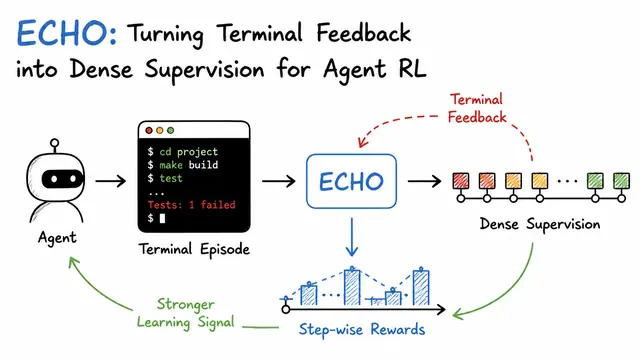
A diagram-rich generated explanation from the public library.
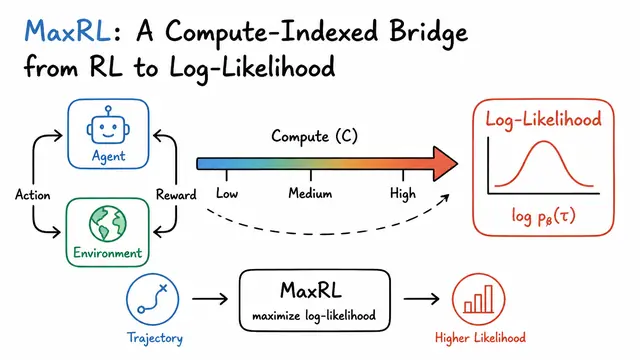
RL framework that approximates maximum likelihood for binary-outcome tasks.
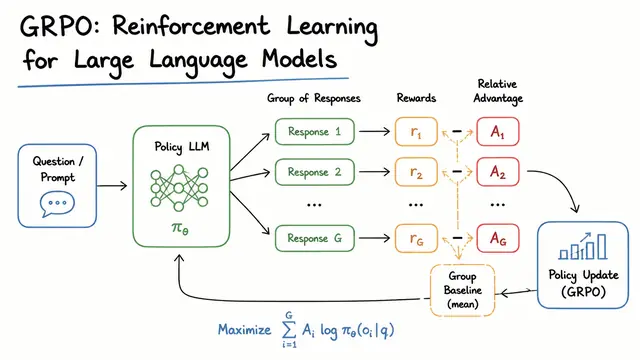
GRPO and RL for LLM's
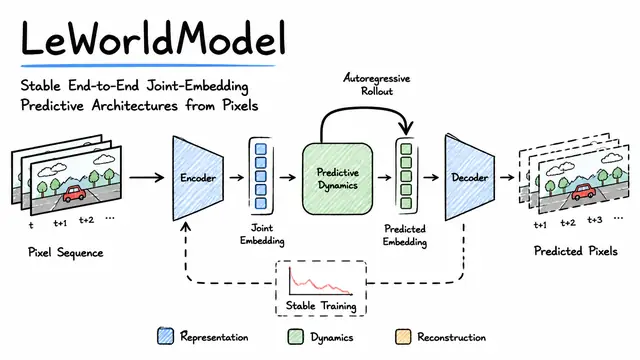
Stable JEPA-based world model that learns and plans from raw pixels.
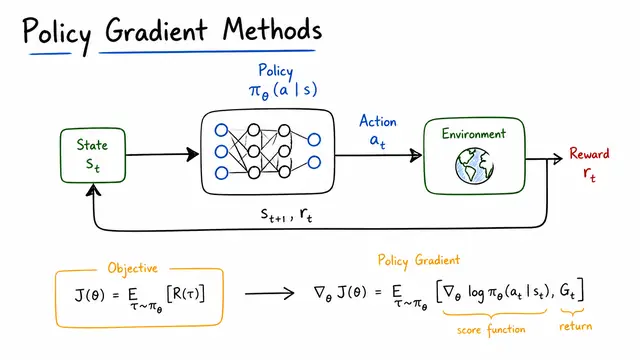
policy gradient methods